Non-invasive suction-cup tag for cetaceans
Limulus Cam-Tag is a temporary suction-cup tag for audiovisual and physiological logging of cetaceans in their natural environment. It integrates a 4K camera built around a Sony IMX678 sensor aimed at surface behaviour, together with a Bar100 pressure sensor for depth (rated to 1000 m), a temperature probe and a 6-axis inertial unit to reconstruct the animal's dive profile and swim pattern.
Telemetry data — depth, temperature, acceleration — is streamed over LoRa to the tracking vessel while the tag remains attached, so deployment status can be checked without physical recovery. Development is carried out in collaboration with CIRCE (Conservation, Information and Research) for use in research campaigns in the Strait of Gibraltar.
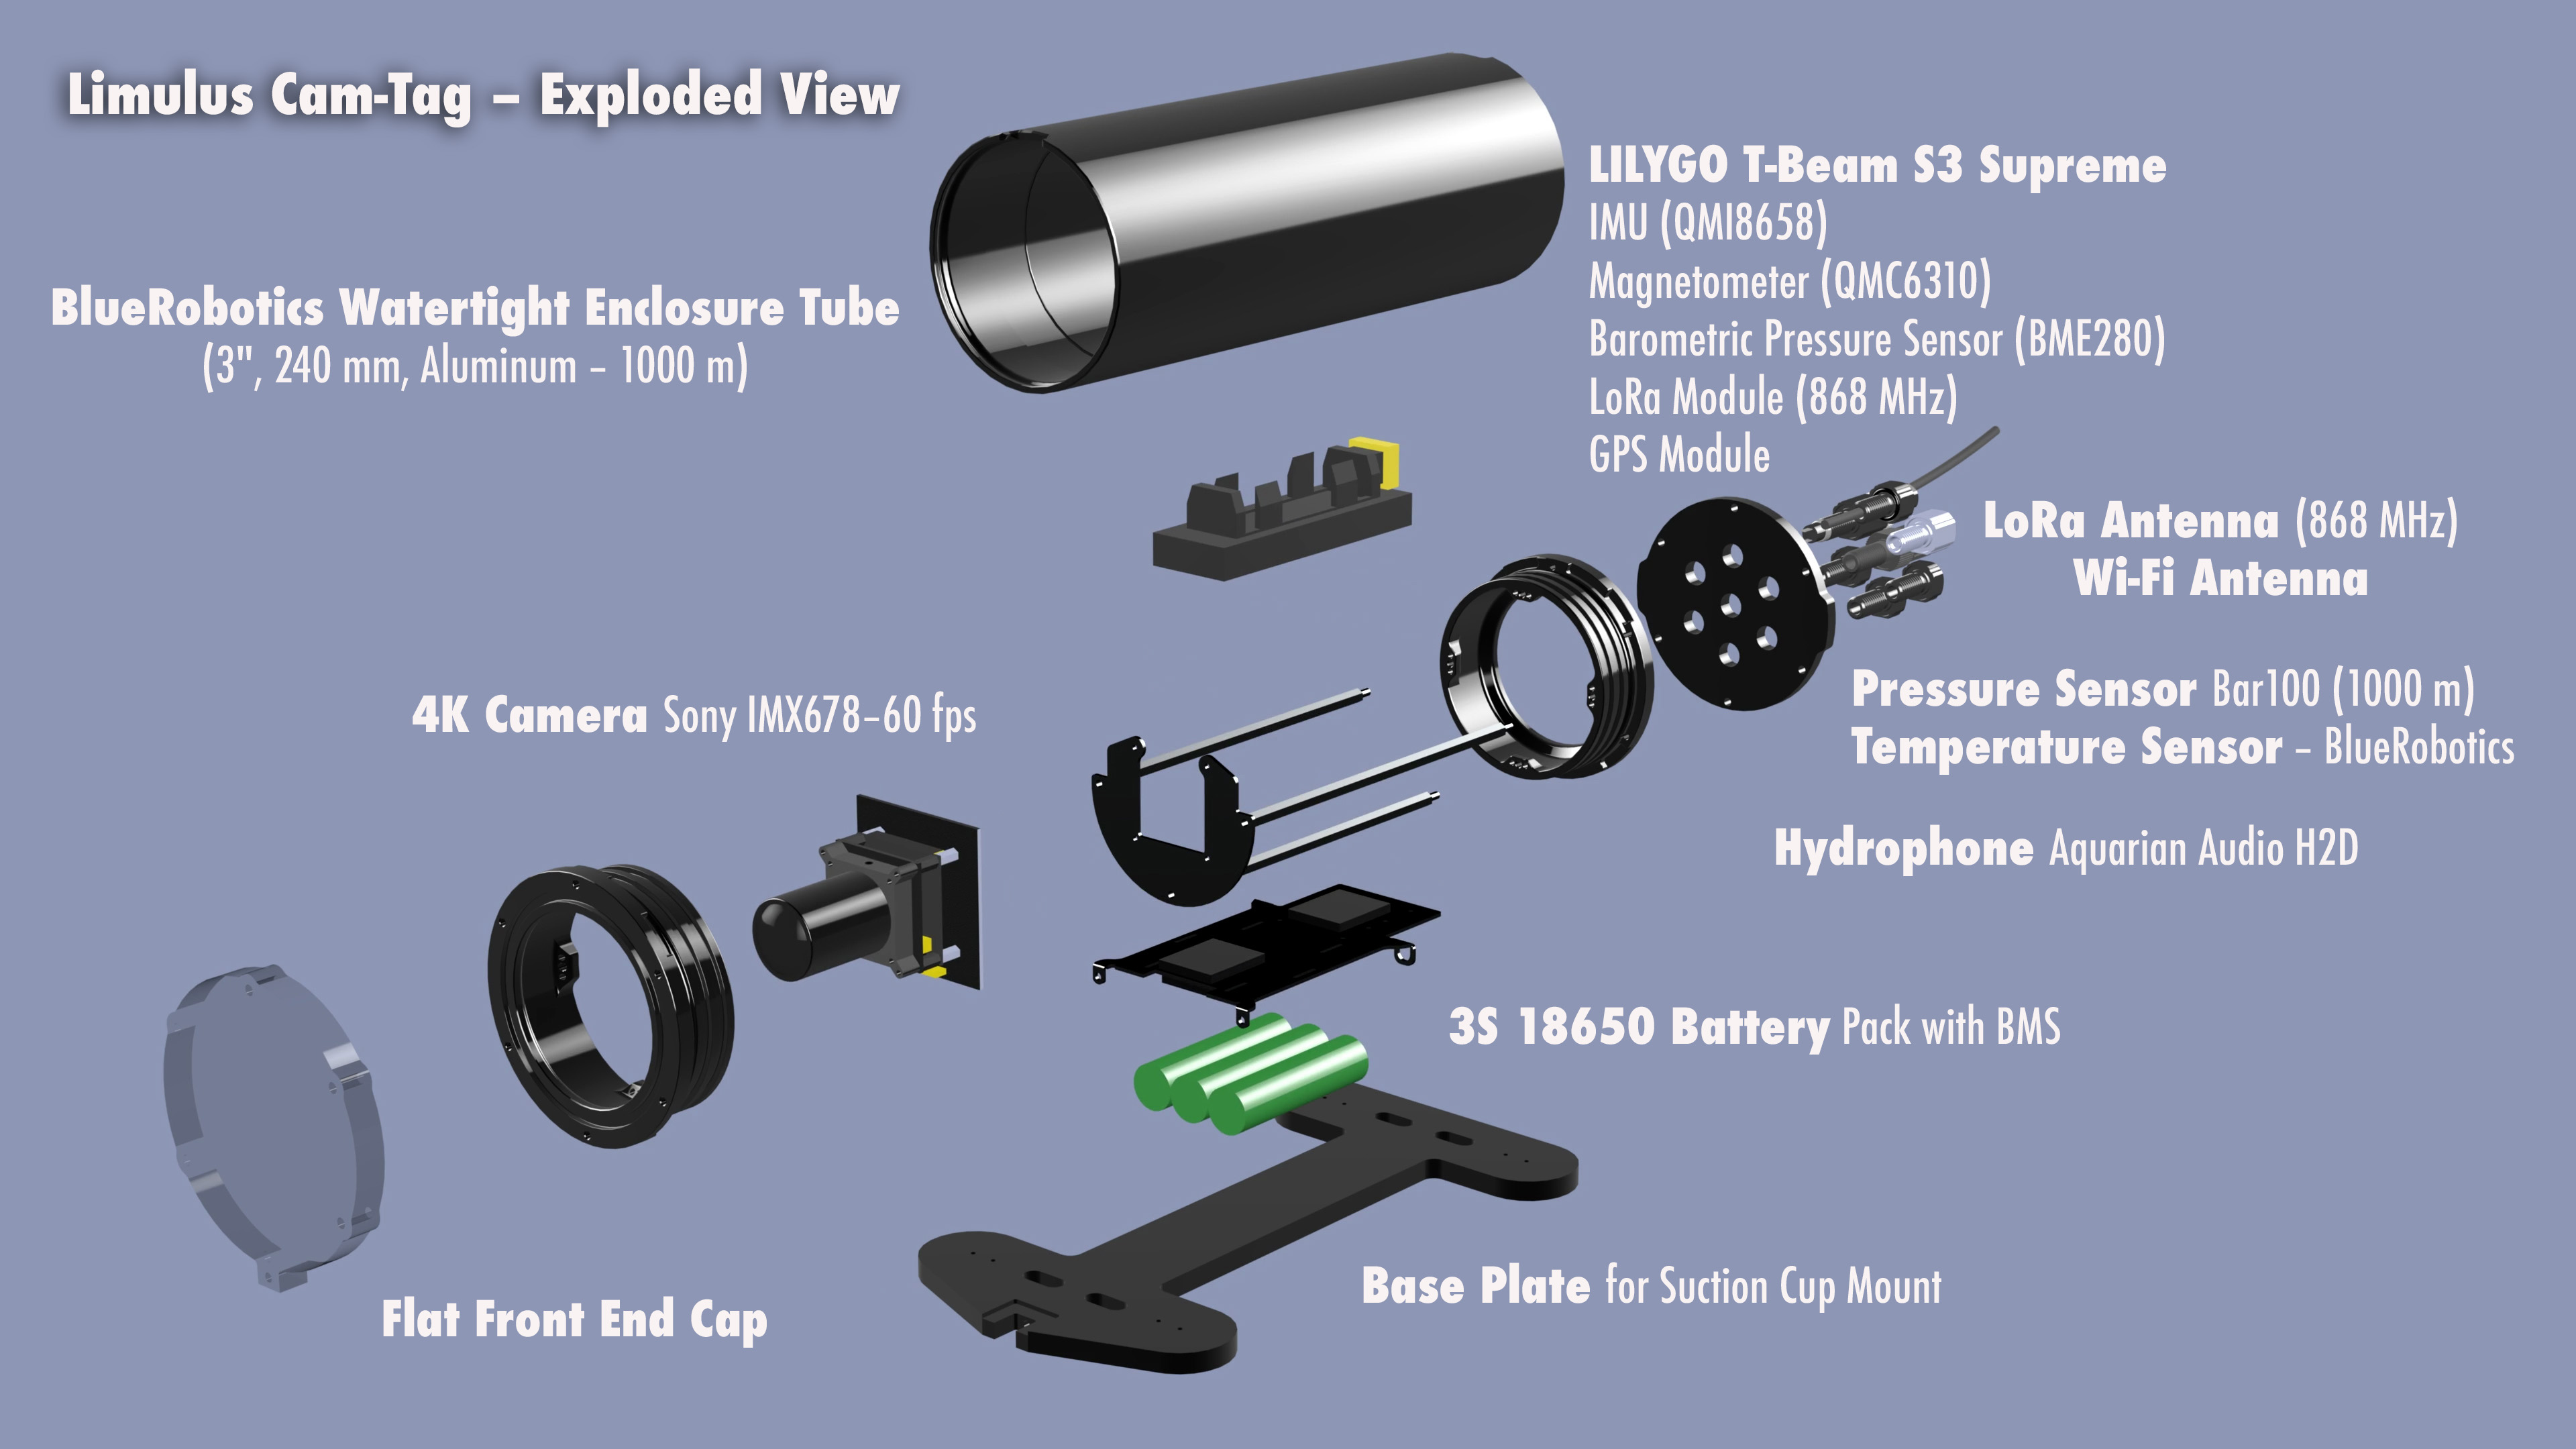
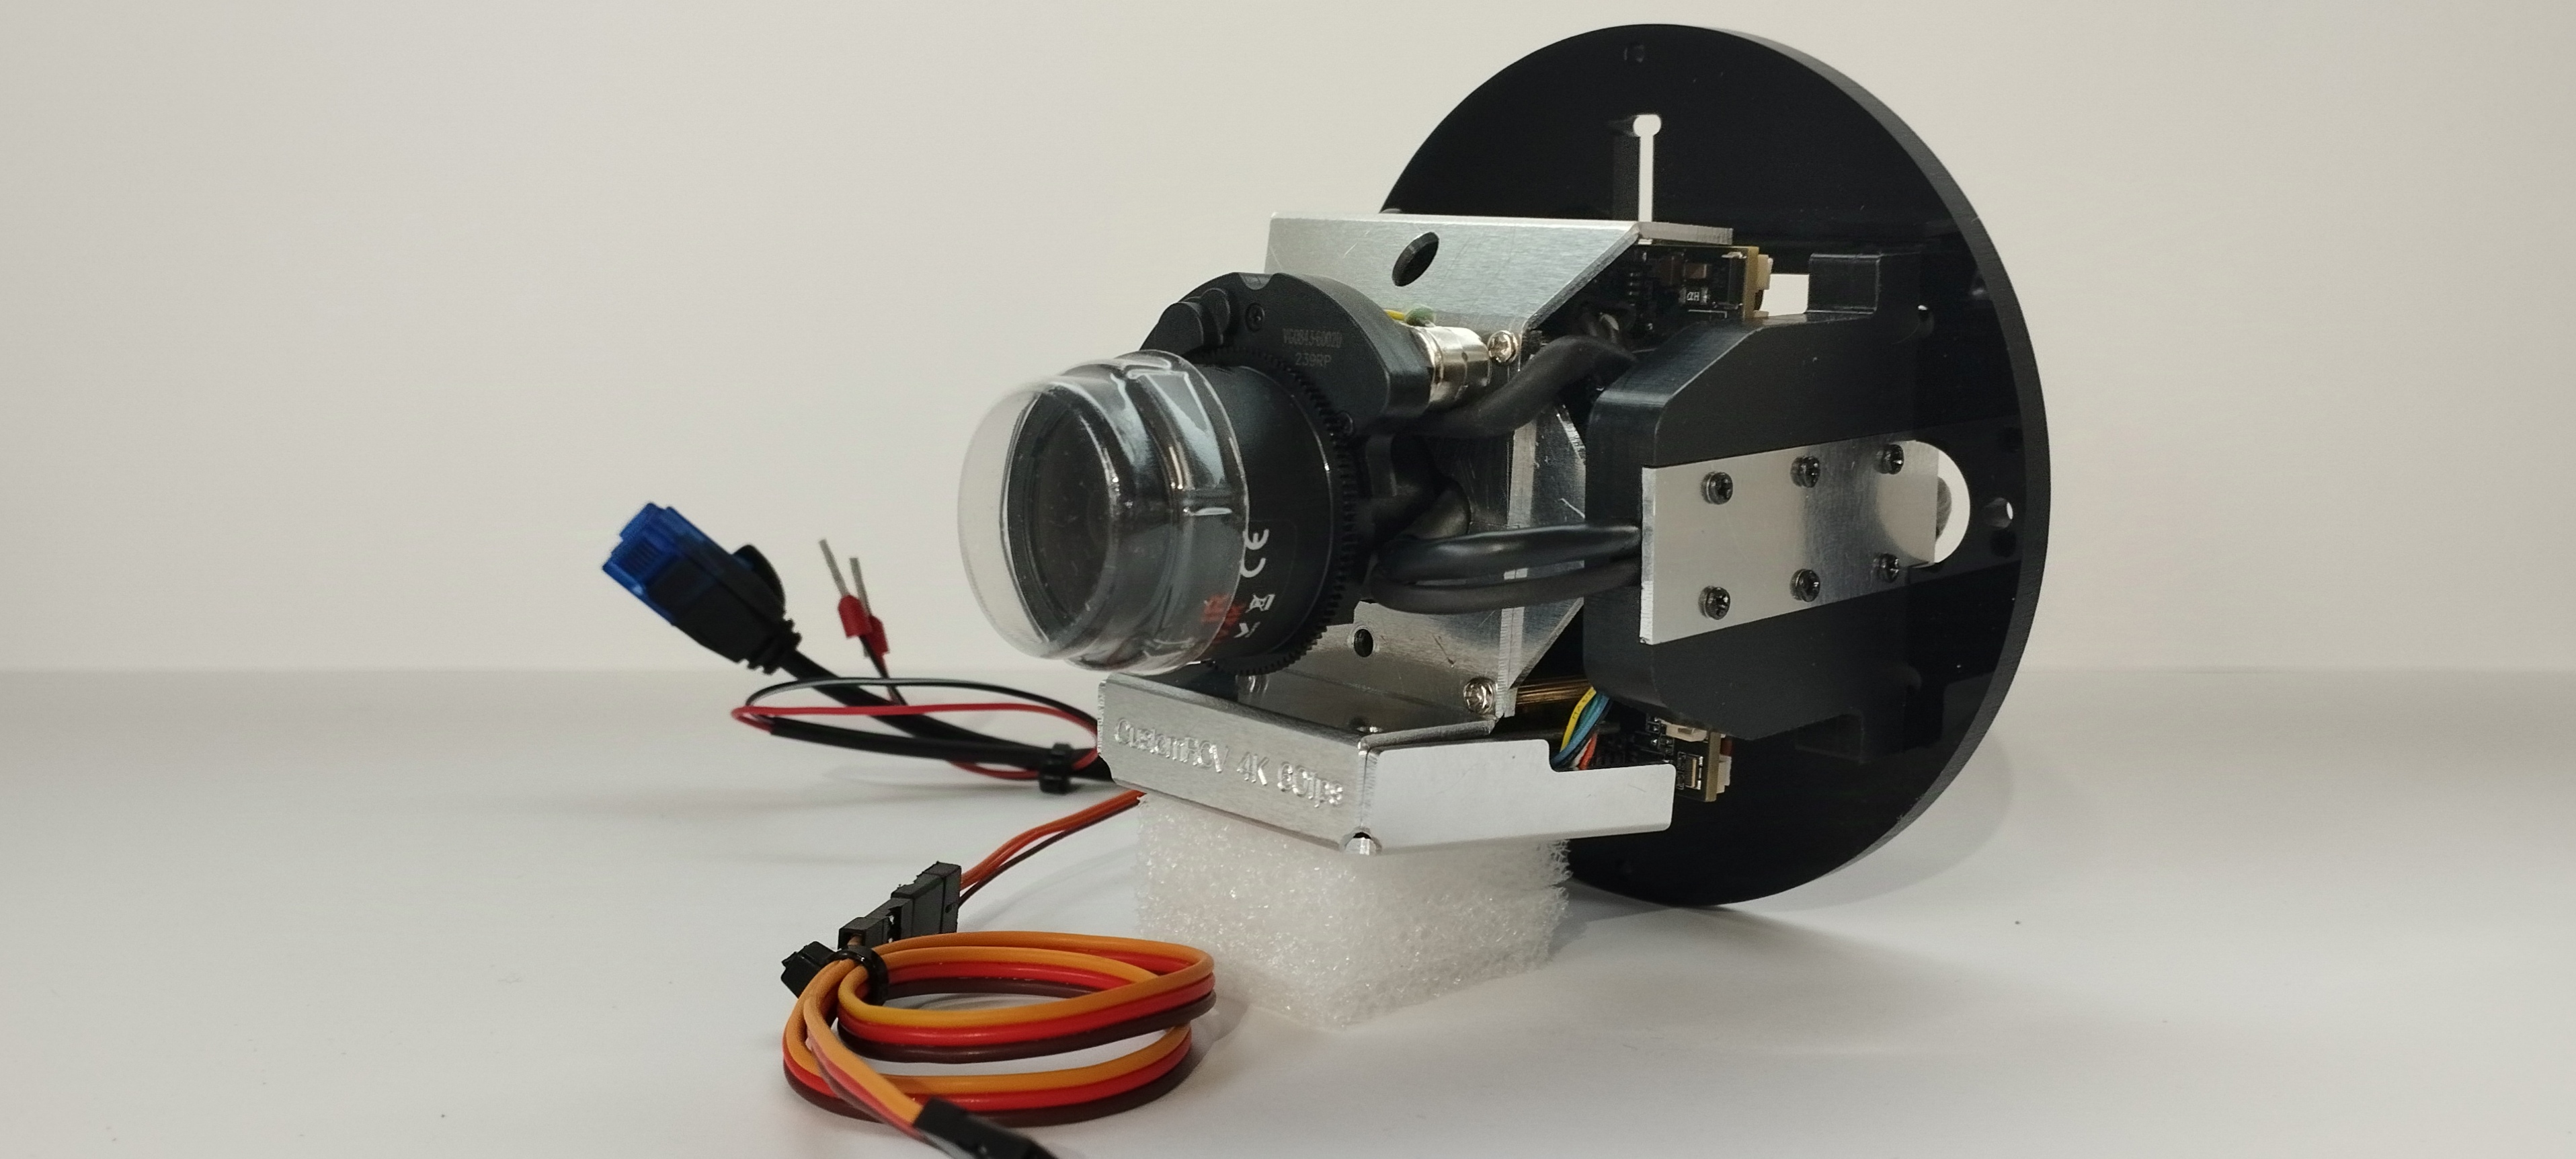
Back-illuminated 8.3 MP CMOS sensor tuned for high dynamic range capture in low light, paired with a wide-angle lens to record surface behaviour and the animal's social context.
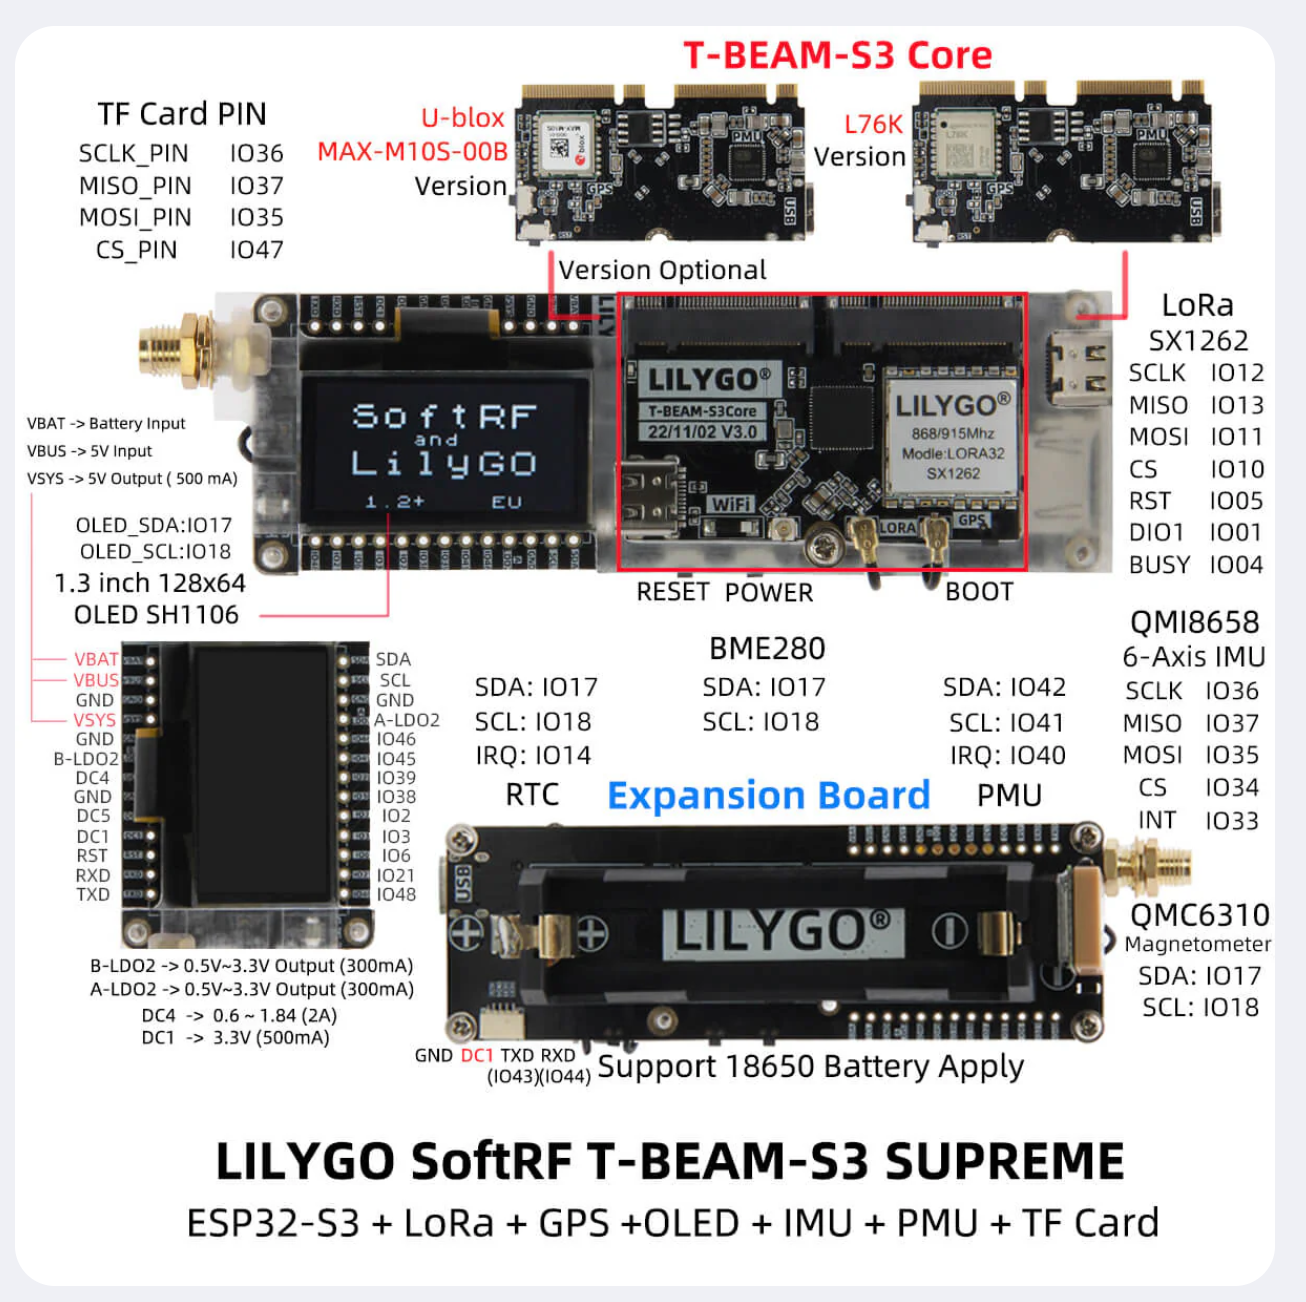
ESP32-S3 controller with onboard LoRa radio, GPS and AXP2101 power management, handling sensor acquisition, local logging and telemetry transmission to the tracking vessel.
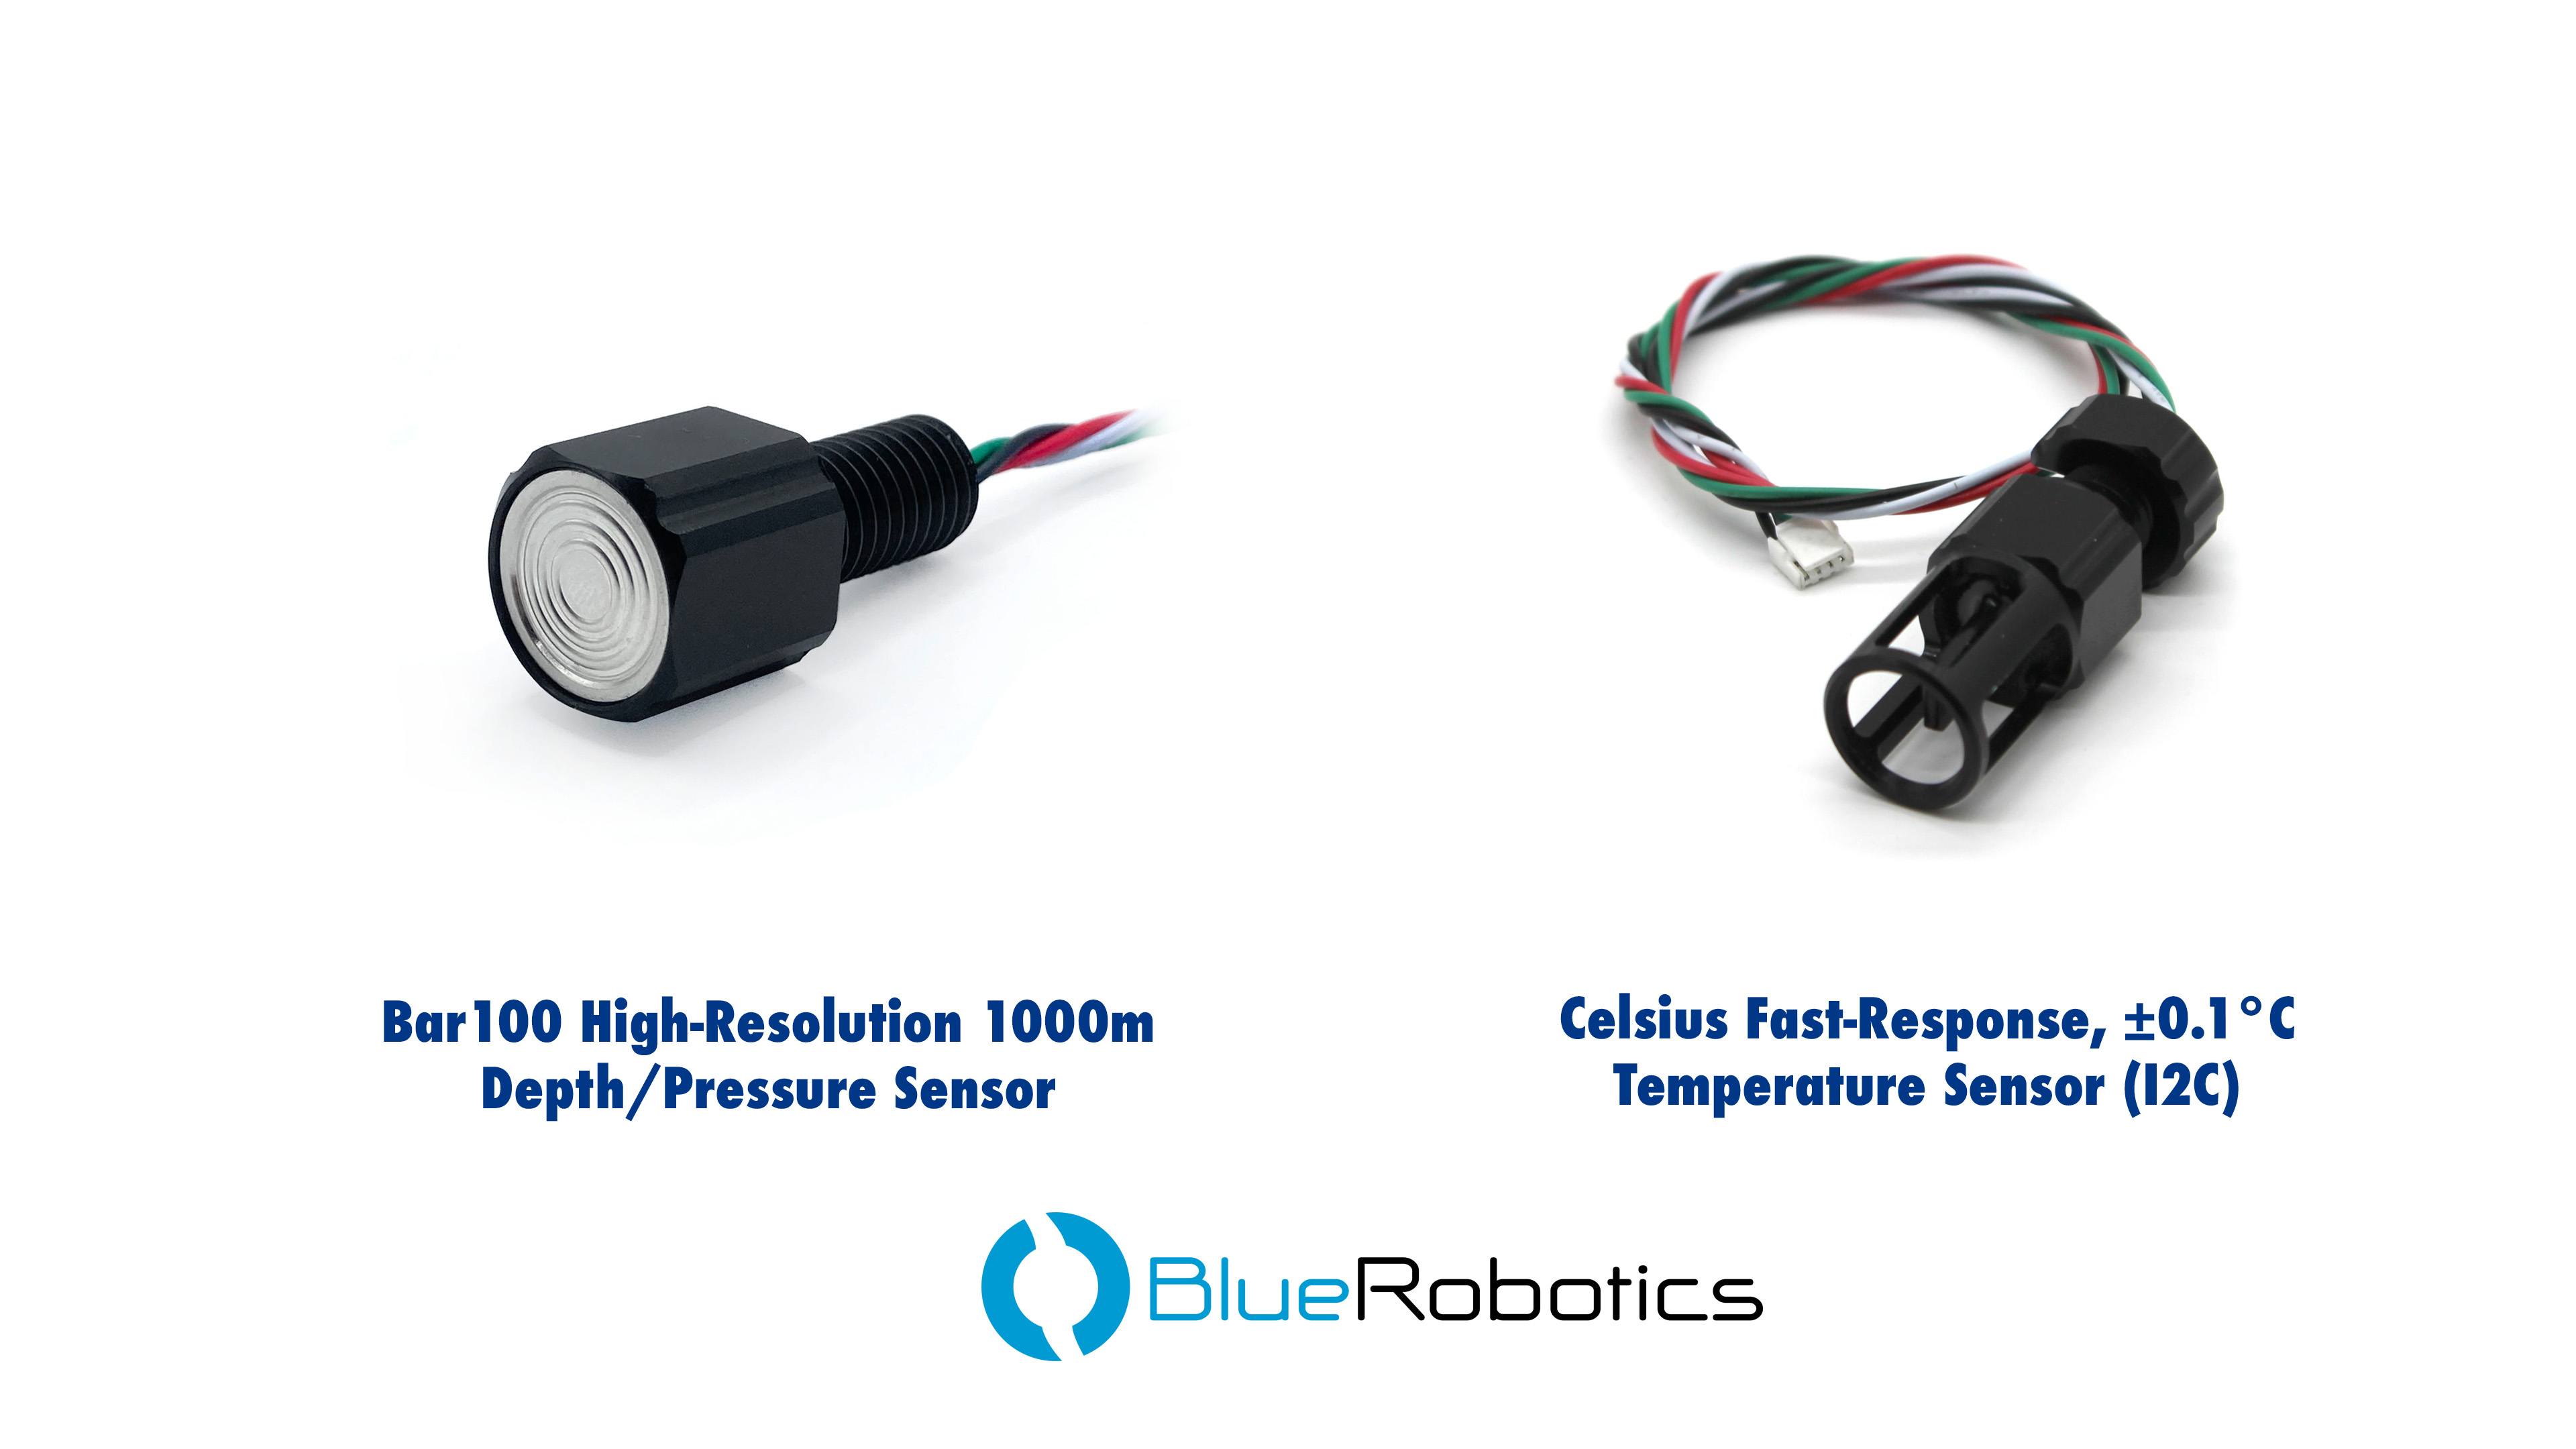
Bar100 pressure sensor rated to 1000 m depth and a Celsius temperature probe, sampled alongside the 6-axis IMU to reconstruct dive profile, ascent rate and ambient thermal conditions.